About Me

I am a PhD student in Quantitative Bioscience in the School of Physics at Georgia Tech, advised by Prof. Daniel I. Goldman. I am also pursuing an MS in Robotics/Computer Science.

My research focuses on locomotion in complex environments (terrestrial and aquatic). I study biological systems to understand how behavior emerges and how these insights can inform robot design.

Before Georgia Tech, I completed an MS in Biomedical Engineering at Columbia University and a BEng in Electrical and Electronic Engineering at University College London.

Publications

Highlighted Papers

  1. 2026

    Water Surface Swimming in a Centipede and its Robophysical Model

    Z. J. Xu, D. Aydin, A. Mustafa, M. B. Levin, J. Lin, T. Wang, D. I. Goldman

    arXiv preprint, 2609.27088

  2. 2026

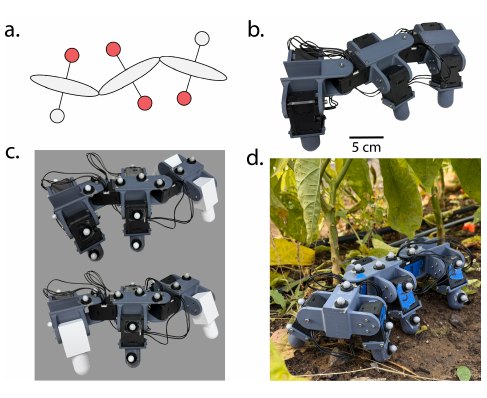
    A Robust Antenna Provides Tactile Feedback in a Multi-Legged Robot

    Z. J. Xu, J. He, D. Aydan, M. Taylor, T. Wang, J. Lin, W. Dyer, D. I. Goldman

    IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026)

All Publications

Show all publicationsShow fewer

The full list includes the highlighted papers above and these additional papers.

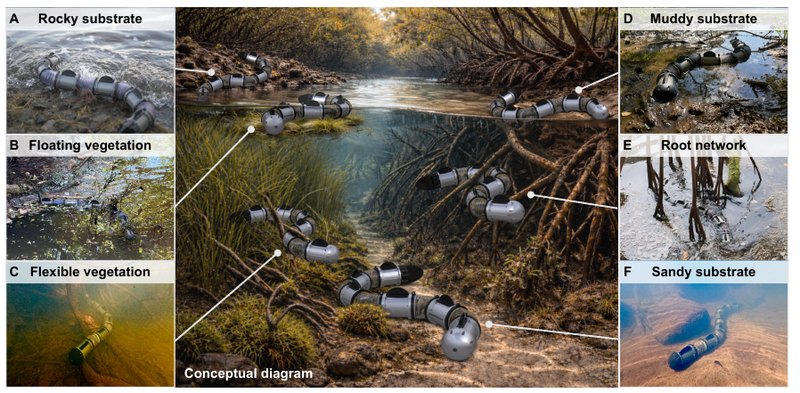
  1. Figure 1: robot navigating cluttered aquatic habitats.
    Figure 1 from the linked publication, page 5; temporary project preview.
    2026

    Three-dimensional hydro-cluttered locomotion by an undulatory robot

    T. Wang, M. Fernandez, G. Tunnicliffe, N. Cornell, J. Duong, D. Dortilus, Z. J. Xu, P. Meza, S. Lublinsky, D. Parikh, J. Lin, E. Grace, D. I. Goldman

    arXiv preprint, 2606.06829

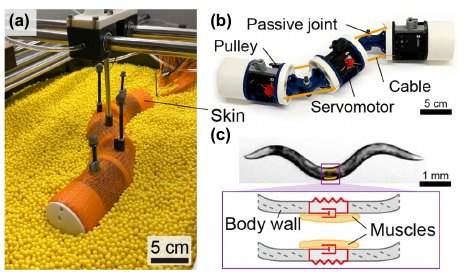
  2. Figure 1: compliant cable-driven swimmer and biological body compliance.
    Figure 1 from the linked publication, page 2; temporary project preview.
    2026

    Optimal Swimming with Body Compliance in an Overdamped Medium

    J. Lin, T. Wang, B. Chong, M. Fernandez, Z. Xu, D. I. Goldman

    Physical Review Applied, 25(5), 054068

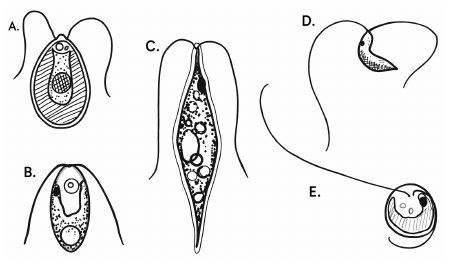
  3. Figure 1: examples of biflagellate microswimmers.
    Figure 1 from the linked publication, page 1; temporary project preview.
    2026

    Tunable Asymmetric Swimming in Biflagellate Microswimmers

    B. J. Walker, C. Moreau, T. L. Robinson, Z. J. Xu, D. I. Goldman, E. A. Gaffney, K. Y. Wan

    Journal of The Royal Society Interface

  4. Figure 1: hexapod robot models and outdoor locomotion.
    Figure 1 from the linked publication, page 1; temporary project preview.
    2026

    Agile Asymmetric Multi-Legged Locomotion: Contact Planning via Geometric Mechanics and Spin Model Duality

    J. Habala, G. B. Margolis, T. Wang, P. Bhatt, J. He, N. Naeem, Z. Xu, P. Agrawal, D. I. Goldman, D. Luo, B. Chong

    arXiv preprint, 2602.09123

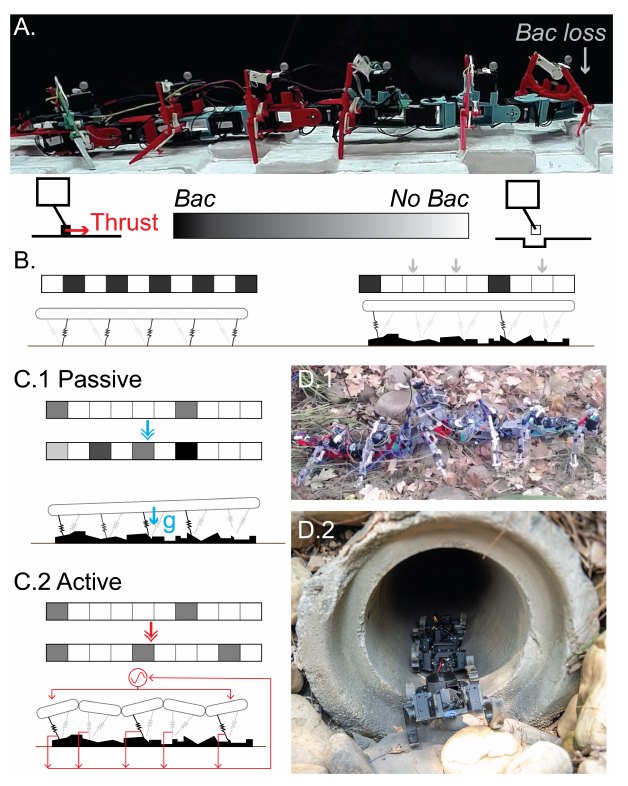
  5. Figure 1: active and passive contact control of multi-legged robots.
    Figure 1 from the linked publication, page 27; temporary project preview.
    2025

    Robust Control for Multi-Legged Elongate Robots in Noisy Environments

    B. Chong, J. He, D. Irvine, T. Wang, E. Flores, D. Soto, J. Lin, Z. Xu, V. R. Nienhusser, G. Blekherman, D. I. Goldman

    arXiv preprint, 2506.15788

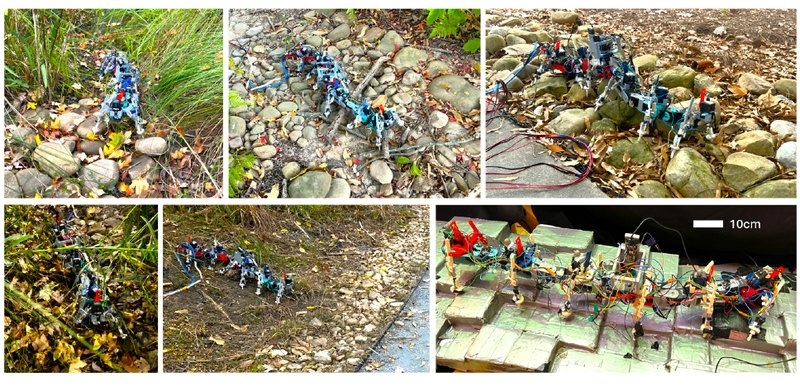
  6. Figure 1: multi-legged robot experiments on rugged terrain.
    Figure 1 from the linked publication, page 2; temporary project preview.
    2025

    Probabilistic Approach to Feedback Control Enhances Multi-Legged Locomotion on Rugged Landscapes

    J. He, B. Chong, J. Lin, Z. Xu, H. Bagheri, E. Flores, D. I. Goldman

    IEEE Transactions on Robotics, 41, 4776–4793

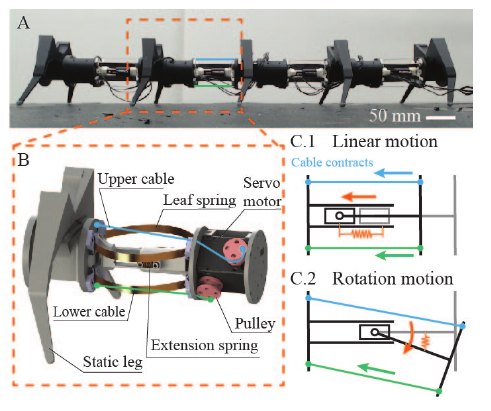
  7. Figure 1: peristaltic robot and its joint actuation mechanisms.
    Figure 1 from the linked publication, page 1; temporary project preview.
    2025

    Addition of a Peristaltic Wave Improves Multi-Legged Locomotion Performance on Complex Terrains

    M. Iaschi, B. Chong, T. Wang, J. Lin, J. He, D. Soto, Z. Xu, D. I. Goldman

    IEEE International Conference on Robotics and Automation (ICRA), 2925–2931

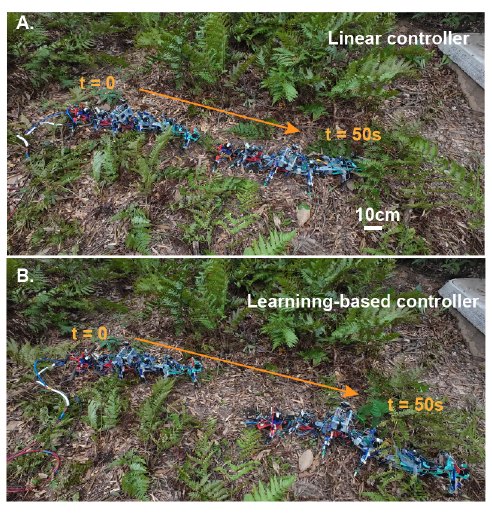
  8. Figure 1: outdoor comparison of linear and learning-based robot control.
    Figure 1 from the linked publication, page 1; temporary project preview.
    2024

    Learning to Enhance Multi-Legged Robot on Rugged Landscapes
    J. He, B. Chong, Z. Xu, S. Ha, D. I. Goldman

    arXiv preprint, 2409.09473

Also on Google Scholar.

Education

2024–present

Georgia Institute of Technology

PhD in Quantitative Bioscience, School of Physics
MS in Robotics/Computer Science, in progress

2022–2024

Columbia University

MS in Biomedical Engineering, Neural Engineering

2018–2022

University College London

BEng in Electrical and Electronic Engineering, minor in Biomedical Engineering

BibTeX · Antenna project

@misc{xu2026robustantennaprovidestactile,
      title={A Robust Antenna Provides Tactile Feedback in a Multi-legged Robot},
      author={Zhaochen J. Xu and Juntao He and Delfin Aydan and Malaika Taylor and Tianyu Wang and Jianfeng Lin and Wesley Dyer and Daniel I. Goldman},
      year={2026},
      eprint={2603.07795},
      archivePrefix={arXiv},
      primaryClass={cs.RO},
      url={https://arxiv.org/abs/2603.07795},
}
Download .bib

BibTeX · Water Surface Swimming in a Centipede and its Robophysical Model

@misc{xu2026watersurfaceswimmingcentipede,
      title={Water Surface Swimming in a Centipede and its Robophysical ModeL}, 
      author={Zhaochen J. Xu and Delfin Aydin and Abdullah Mustafa and Margarita B. Levin and Jianfeng Lin and Tianyu Wang and Daniel I. Goldman},
      year={2026},
      eprint={2609.27088},
      archivePrefix={arXiv},
      primaryClass={cs.RO},
      url={https://arxiv.org/abs/2609.27088}, 
}
Download .bibarXiv export source

BibTeX · Three-dimensional hydro-cluttered locomotion by an undulatory robot

@misc{wang2026threedimensionalhydroclutteredlocomotionundulatory,
      title={Three-dimensional hydro-cluttered locomotion by an undulatory robot}, 
      author={Tianyu Wang and Matthew Fernandez and Galen Tunnicliffe and Nikolas Cornell and Justin Duong and Donoven Dortilus and Zhaochen J. Xu and Patricia Meza and Sean Lublinsky and Darsh Parikh and Jianfeng Lin and Emily Grace and Daniel I. Goldman},
      year={2026},
      eprint={2606.06829},
      archivePrefix={arXiv},
      primaryClass={cs.RO},
      url={https://arxiv.org/abs/2606.06829}, 
}
Download .bibarXiv export source

BibTeX · Optimal Swimming with Body Compliance in an Overdamped Medium

@misc{lin2025optimalswimmingbodycompliance,
      title={Optimal swimming with body compliance in an overdamped medium}, 
      author={Jianfeng Lin and Tianyu Wang and Baxi Chong and Matthew Fernandez and Zhaochen Xu and Daniel I. Goldman},
      year={2025},
      eprint={2510.03457},
      archivePrefix={arXiv},
      primaryClass={cs.RO},
      url={https://arxiv.org/abs/2510.03457}, 
}
Download .bibarXiv export source

BibTeX · Tunable Asymmetric Swimming in Biflagellate Microswimmers

@article{Walker_2026,
   title={Tunable asymmetric swimming in biflagellate microswimmers},
   volume={23},
   ISSN={1742-5662},
   url={http://dx.doi.org/10.1098/rsif.2026.0195},
   DOI={10.1098/rsif.2026.0195},
   number={241},
   journal={Journal of the Royal Society Interface},
   publisher={The Royal Society},
   author={Walker, Benjamin J. and Moreau, Clément and Robinson, Tommie L. and Xu, Zhaochen J. and Goldman, Daniel I. and Gaffney, Eamonn A. and Wan, Kirsty Y.},
   year={2026},
   month=Aug }
Download .bibarXiv export source

BibTeX · Agile Asymmetric Multi-Legged Locomotion: Contact Planning via Geometric Mechanics and Spin Model Duality

@misc{habala2026agileasymmetricmultileggedlocomotion,
      title={Agile asymmetric multi-legged locomotion: contact planning via geometric mechanics and spin model duality}, 
      author={Jackson Habala and Gabriel B. Margolis and Tianyu Wang and Pratyush Bhatt and Juntao He and Naheel Naeem and Zhaochen Xu and Pulkit Agrawal and Daniel I. Goldman and Di Luo and Baxi Chong},
      year={2026},
      eprint={2602.09123},
      archivePrefix={arXiv},
      primaryClass={cs.RO},
      url={https://arxiv.org/abs/2602.09123}, 
}
Download .bibarXiv export source

BibTeX · Robust Control for Multi-Legged Elongate Robots in Noisy Environments

@misc{chong2025robustcontrolmultileggedelongate,
      title={Robust control for multi-legged elongate robots in noisy environments}, 
      author={Baxi Chong and Juntao He and Daniel Irvine and Tianyu Wang and Esteban Flores and Daniel Soto and Jianfeng Lin and Zhaochen Xu and Vincent R Nienhusser and Grigoriy Blekherman and Daniel I. Goldman},
      year={2025},
      eprint={2506.15788},
      archivePrefix={arXiv},
      primaryClass={cs.RO},
      url={https://arxiv.org/abs/2506.15788}, 
}
Download .bibarXiv export source

BibTeX · Probabilistic Approach to Feedback Control Enhances Multi-Legged Locomotion on Rugged Landscapes

@article{He_2025,
   title={Probabilistic Approach to Feedback Control Enhances Multilegged Locomotion on Rugged Landscapes},
   volume={41},
   ISSN={1941-0468},
   url={http://dx.doi.org/10.1109/TRO.2025.3593133},
   DOI={10.1109/tro.2025.3593133},
   journal={IEEE Transactions on Robotics},
   publisher={Institute of Electrical and Electronics Engineers (IEEE)},
   author={He, Juntao and Chong, Baxi and Lin, Jianfeng and Xu, Zhaochen and Bagheri, Hosain and Flores, Esteban and Goldman, Daniel I.},
   year={2025},
   pages={4776–4793} }
Download .bibarXiv export source

BibTeX · Addition of a Peristaltic Wave Improves Multi-Legged Locomotion Performance on Complex Terrains

@misc{iaschi2024additionperistalticwaveimproves,
      title={Addition of a peristaltic wave improves multi-legged locomotion performance on complex terrains}, 
      author={Massimiliano Iaschi and Baxi Chong and Tianyu Wang and Jianfeng Lin and Juntao He and Daniel Soto and Zhaochen Xu and Daniel I Goldman},
      year={2024},
      eprint={2410.01046},
      archivePrefix={arXiv},
      primaryClass={cs.RO},
      url={https://arxiv.org/abs/2410.01046}, 
}
Download .bibarXiv export source

BibTeX · Learning to Enhance Multi-Legged Robot on Rugged Landscapes
@misc{he2024learningenhancemultileggedrobot,
      title={Learning to enhance multi-legged robot on rugged landscapes}, 
      author={Juntao He and Baxi Chong and Zhaochen Xu and Sehoon Ha and Daniel I. Goldman},
      year={2024},
      eprint={2409.09473},
      archivePrefix={arXiv},
      primaryClass={cs.RO},
      url={https://arxiv.org/abs/2409.09473}, 
}
Download .bibarXiv export source